W-ROBOT · Electric grippers
W-ROBOT electric grippers.W-ROBOT 電動夾爪。
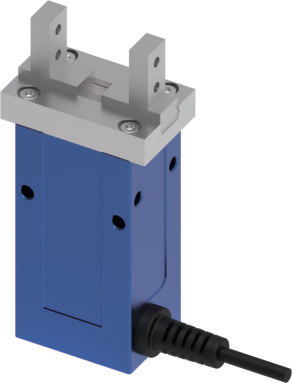
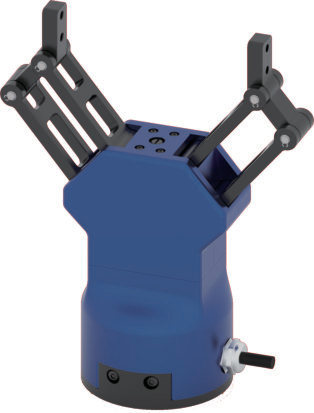
Two-finger parallel, three-finger and four-finger centric, collaborative, rotary, and long-stroke. The jaws are on the product. The controller is inside the gripper. Figures on this site come from the selection manual. 兩指平動、三指與四指對心、協作、旋轉,以及長行程。夾爪本體看得到手指。控制器內置。本站數字來自選型手冊。
- 8 series in manual V1.3.1205手冊 V1.3.1205 的 8 個系列
- Stroke 6 mm to 265 mm行程 6 mm 至 265 mm
- DC 24 V ±10%DC 24 V ±10%
- Built-in controller內置控制器
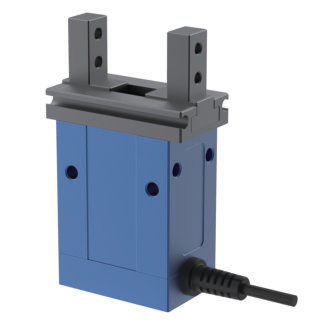
Choose by mechanism, not by a cart.按機構選,而不是放進購物車。
Each series below is a family in the W-ROBOT selection manual. Open one to see the models and the numbers that the manual states consistently.下面每個系列都是 W-ROBOT 選型手冊裡的一個家族。點進去看型號,以及手冊前後一致的數字。
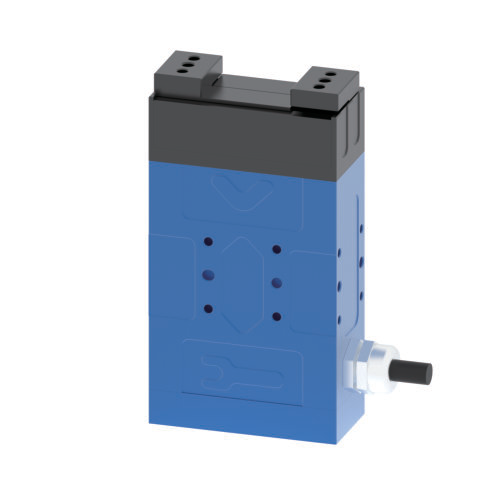
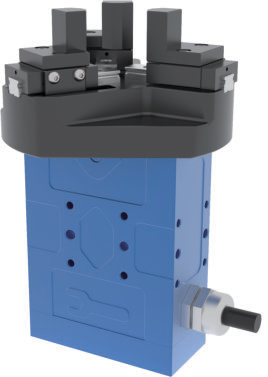
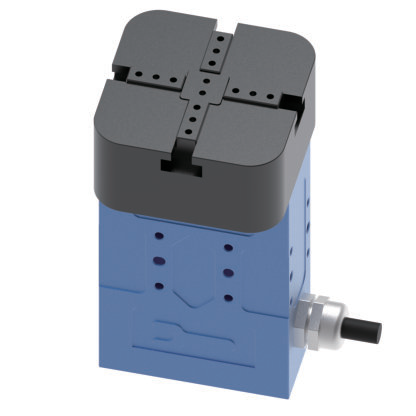
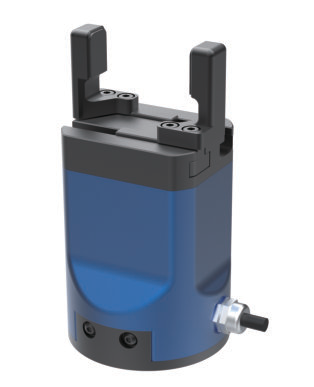
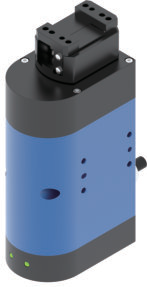
A selection starts with the part.選型從工件開始。
Part and motion工件與動作
Size range, mass, and whether the part is only gripped, centred, or also rotated.尺寸範圍、質量,以及只是夾持、需要對心,還是還要旋轉。
Stroke, force, interface行程、力、介面
Match a series, then check one-way time, repeatability, and whether you need I/O only, Modbus, or EtherCAT.先對上系列,再核對單程時間、重複精度,以及要 I/O、Modbus 還是 EtherCAT。
Inquiry, not a price詢價,不標價
Send the worksheet by email or WhatsApp. This site does not list prices or take orders online.用電郵或 WhatsApp 送出工況。本站不標價,也不在線上下單。
Applications named in the manual手冊列出的應用
Where the manual places these grippers.手冊把這些夾爪放在哪些行業。
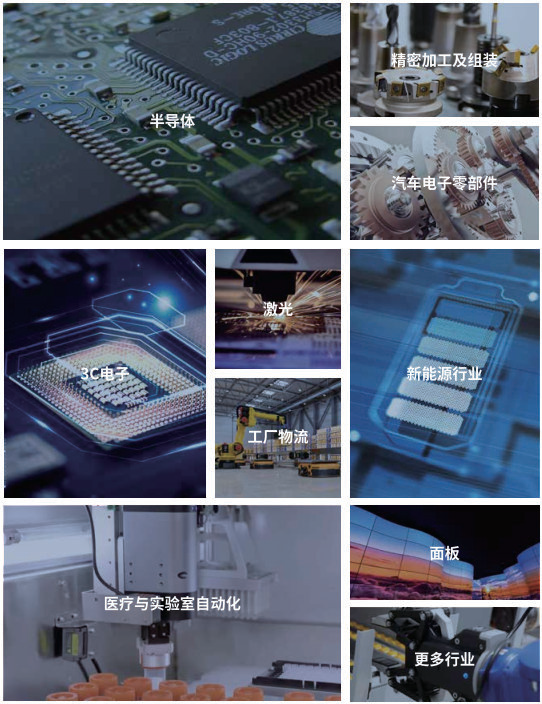
Semiconductor, precision machining and assembly, automotive electronics, 3C, laser, new energy, factory logistics, display panels, and medical automation. These are application names from the manual, not customer stories.半導體、精密加工與裝配、汽車電子、3C、激光、新能源、工廠物流、顯示面板,以及醫療自動化。這些是手冊裡的應用名稱,不是客戶案例。
Read the application list查看應用列表