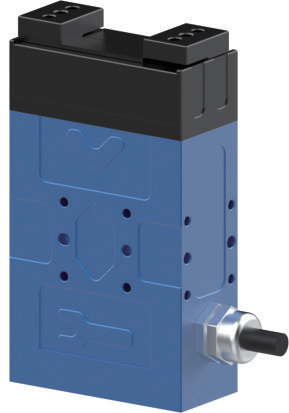
EPG2-26-15
0–26 mm · 6–15 N · 0.3 kg · 0.3 s · 400 g · ±0.02 mm
W-ROBOT · Product catalog
Every model name below is printed in the W-ROBOT selection manual 智能电动夹爪-产品选型手册, version V1.3.1205. Gripping force on adjustable models is the sustained range from the parameter page. A blank cell means the overview and the parameter page do not state the same number.下面每個型號名稱都印在 W-ROBOT《智能电动夹爪-产品选型手册》版本 V1.3.1205。可調機型的夾持力採用參數頁的持續範圍。空白表示概覽與參數頁數字不一致。
EPGS
The manual describes EPGS as a simple electric replacement for a pneumatic gripper. Control is three wires: 24 V, 0 V, and one I/O line. High level (3–24 V) opens the jaws. Low level (0–1 V) closes them. Optional magnetic-switch detection is mentioned for the series. The series introduction also names mounting groups EPGS-6/8/16 and EPGS-8P/12P. Parameter pages in this edition cover the three models below.手冊把 EPGS 寫成可以替換氣爪的簡易電爪。控制只有三根線:24 V、0 V 和一根 I/O。高電平(3–24 V)張開,低電平(0–1 V)閉合。系列介紹提到可選磁性開關,並寫了安裝組 EPGS-6/8/16 與 EPGS-8P/12P。這一版的參數頁覆蓋下面三個型號。
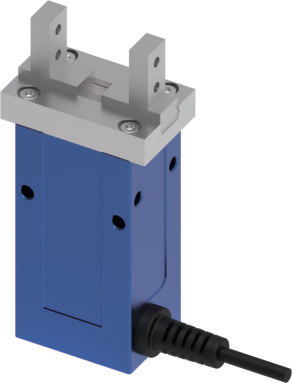
| # | Colour顏色 | Function定義 |
|---|---|---|
| 1 | Red紅 | 24 V + |
| 2 | Black黑 | 0 V |
| 3 | Yellow黃 | I/O |
EPG2
Adjustable gripping force and stroke, drop detection, Modbus RTU (RS485) plus I/O, magnetic encoder, force-control accuracy ±10% on the parameter pages, IP40. Standard ordering code is side exit, cable extension L2, and no brake — except EPG2-50-150, where the ordering legend says the brake is standard and the parameter page says it is not. That brake statement is omitted. Fingertips are described as changeable.夾持力與行程可調,帶掉落檢測,Modbus RTU(RS485)加 I/O,磁編碼器,參數頁的力控精度為 ±10%,IP40。標準訂貨為側面出線、延長線 L2、無抱閘。EPG2-50-150 例外:訂貨說明寫標準帶抱閘,參數頁寫標配無,所以抱閘一項不列出。手冊寫指尖可換。
0–26 mm · 6–15 N · 0.3 kg · 0.3 s · 400 g · ±0.02 mm
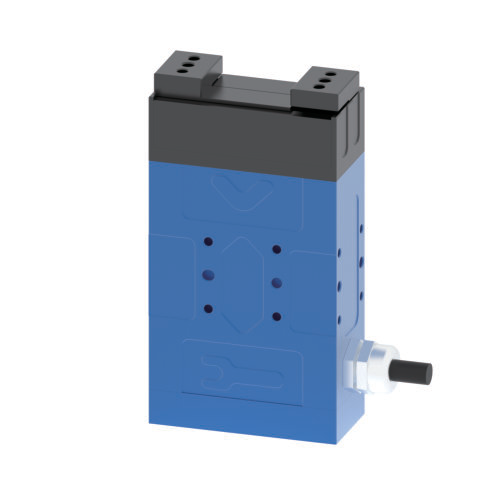
0–26 mm · 15–50 N · 0.8 kg · 0.3 s · 420 g · ±0.02 mm
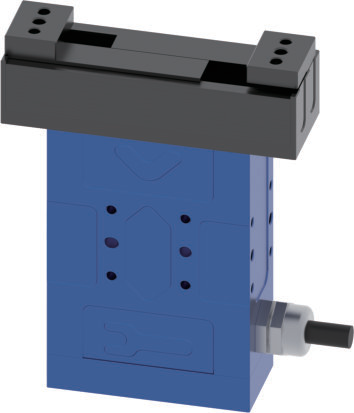
0–50 mm · 15–50 N · 0.8 kg · 0.5 s · 520 g · ±0.02 mm
EPG3
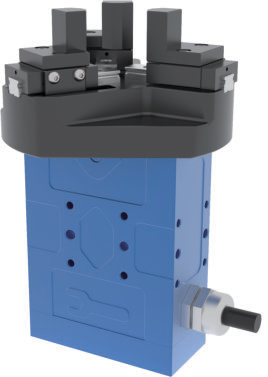
For irregular parts, in the overview note. The contents and the parameter page name this model EPG3-10-50. The overview table prints EPG3-10-10 on the same row of numbers. Single-finger stroke. No brake on the standard build. IP40. Modbus RTU + I/O.概覽備註寫「夾持不規則物體」。目錄和參數頁的型號是 EPG3-10-50。概覽表同一行印成 EPG3-10-10。行程按單指。標準版本無抱閘。IP40。Modbus RTU + I/O。
EPG4
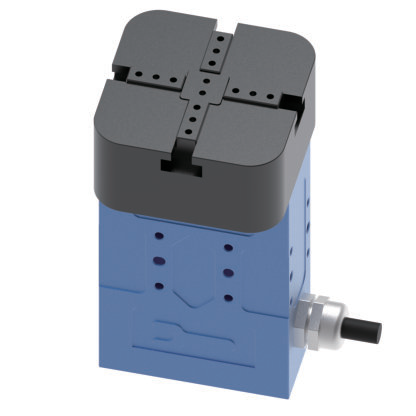
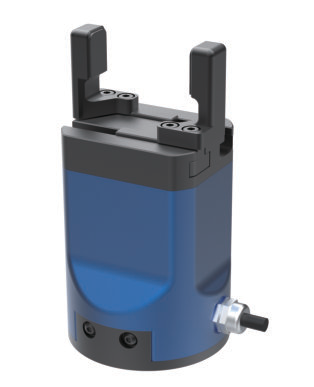
Four-finger centric. Single-finger stroke 0–10 mm. Size excluding fingers 55 × 55 × 105.9 mm. Static load Fz 140 N. Standard build has no power-off brake. IP40. Modbus RTU + I/O. Current 0.3 A.四指對心。單指行程 0–10 mm。不含夾指外形 55 × 55 × 105.9 mm。靜負載 Fz 140 N。標準版本無斷電抱閘。IP40。Modbus RTU + I/O。持續電流 0.3 A。
EPGC
Collaborative two-finger gripper, described as mainly for a cobot arm. Power-off self-lock, drop detection, plug-and-play. Bottom flange mounting. Power-off brake is the standard build on the ordering legend, the overview note, and the parameter page. IP54. Size excluding fingers 75 × 75 × 102 mm. Fz 300 N. Noise ≤50 dB. Current 0.6 A.協作型兩指電爪,手冊寫明主要搭配協作機械臂。掉電自鎖、掉落檢測、即插即用。底部法蘭安裝。訂貨說明、概覽備註和參數頁都寫標準帶斷電抱閘。IP54。不含夾指外形 75 × 75 × 102 mm。Fz 300 N。噪音 ≤50 dB。電流 0.6 A。
Y-type · EPG2-100-50
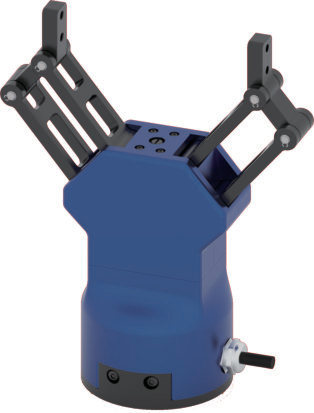
Two-finger Y linkage, mainly for a cobot arm. Bottom flange. Adjustable stroke and force, drop detection. Drive is a trapezoidal screw plus linkage. Open size 75 × 156 × 196 mm. Closed size 75 × 86 × 208 mm. Fz 150 N, Mx 2 N·m, My 1.5 N·m, Mz 1.5 N·m. IP40. Current 0.6 A. The ordering code treats “no brake” as standard, while the parameter page says the power-off hold is fitted. That point is not stated as a fact.兩指 Y 型連桿,主要搭配協作機械臂。底部法蘭。行程與夾持力可調,帶掉落檢測。傳動為梯形絲桿加連桿。張開外形 75 × 156 × 196 mm,閉合 75 × 86 × 208 mm。Fz 150 N,Mx 2 N·m,My 1.5 N·m,Mz 1.5 N·m。IP40。電流 0.6 A。訂貨代碼把「無抱閘」當標準,參數頁寫標配有斷電自鎖。這一項不當作既定事實。
ERG
Grip and infinite rotation. Dual servo. Front, rear, left and bottom mounting. Rated torque 0.5 N·m, peak 1.5 N·m, minimum 0.06 N·m. Maximum rotation speed 1080°/s. Size 70 × 47 × 148 mm. Fz 200 N. No brake on the standard build. The parameter page prints the encoder as Hall in Chinese and magnetic in English, so the encoder type is omitted. IP40. Current 1.5 A.夾持加無限旋轉。雙伺服。前、後、左、底可安裝。額定扭矩 0.5 N·m,峰值 1.5 N·m,最小 0.06 N·m。最大轉速 1080°/s。外形 70 × 47 × 148 mm。Fz 200 N。標準版本無抱閘。參數頁中文寫霍爾、英文寫磁編,編碼器類型因此不列。IP40。電流 1.5 A。
ERGD
The contents and the overview name this gripper ERGD-30-35 and print a 30 mm stroke. The parameter page and its ordering code name it ERGD-25-35 and print a 25 mm stroke. Stroke is not listed.目錄和概覽把這台寫成 ERGD-30-35,行程 30 mm。參數頁和訂貨代碼寫成 ERGD-25-35,行程 25 mm。行程不列出。
The overview remark says zero backlash and high precision. Infinite rotation, ±0.05° rotary repeatability, 1080°/s, rated torque 0.25 N·m, peak 0.5 N·m, minimum 0.06 N·m. Size 50 × 50 × 140.1 mm. Fz 200 N. No brake on the standard build. Encoder wording disagrees inside the parameter page, so it is omitted. IP40. Current 1.5 A.概覽備註寫零背隙、高精度。無限旋轉,旋轉重複精度 ±0.05°,1080°/s,額定扭矩 0.25 N·m,峰值 0.5 N·m,最小 0.06 N·m。外形 50 × 50 × 140.1 mm。Fz 200 N。標準版本無抱閘。參數頁裡編碼器中英文字不一致,所以不列。IP40。電流 1.5 A。
EPGL
Long-stroke parallel gripper. Stroke 265 mm is on both the overview and the parameter page. Repeatability ±0.1 mm, noise ≤65 dB, size 443 × 60 × 108 mm, current 1.8 A, absolute encoder, IP40. Interface is Modbus RTU, I/O and EtherCAT. Power-off brake is the standard build. Fz 600 N, Mx 260 N·m, My 336 N·m, Mz 142 N·m.長行程平動電爪。行程 265 mm 在概覽和參數頁一致。重複定位精度 ±0.1 mm,噪音 ≤65 dB,外形 443 × 60 × 108 mm,電流 1.8 A,絕對值編碼器,IP40。介面為 Modbus RTU、I/O 與 EtherCAT。標準版本帶斷電抱閘。Fz 600 N,Mx 260 N·m,My 336 N·m,Mz 142 N·m。
Not listed, because the pages disagree: gripping force (overview 800 N, parameter page 400–1100 N per side), recommended load (12 kg vs 15 kg), one-way time (2.2 s vs 6 mm / 0.3 s), weight (4500 g vs 6200 g).以下不列出,因為兩頁不一致:夾持力(概覽 800 N,參數頁單邊 400–1100 N)、建議負載(12 kg 對 15 kg)、單程時間(2.2 s 對 6 mm / 0.3 s)、重量(4500 g 對 6200 g)。
Shared supply on these models: DC 24 V ±10%, controller inside the gripper, 0–40°C, 20–85% RH. Certification line in the manual is printed “CE, FCC, ROSH”.這些型號共通的供電:DC 24 V ±10%,控制器內置,0–40°C,相對濕度 20–85%。手冊認證欄印為「CE、FCC、ROSH」。
| Model型號 | Stroke行程 | Grip force夾持力 | Load建議負載 | One way單程 | Weight重量 | Repeatability重複精度 | Interface介面 |
|---|---|---|---|---|---|---|---|
| EPGS-6-10 | 6 mm | 10 N ±20% | 0.2 kg | 0.1 s | 160 g | ±0.1 mm | I/O |
| EPGS-8-10 | 8 mm | 10 N ±20% | 0.2 kg | 0.1 s | — | ±0.1 mm | I/O |
| EPGS-12-15 | 12 mm | 15 N ±20% | 0.26 kg | 0.15 s | 180 g | ±0.1 mm | I/O |
| EPG2-26-15 | 0–26 mm | 6–15 N | 0.3 kg | 0.3 s | 400 g | ±0.02 mm | Modbus RTU + I/O |
| EPG2-26-50 | 0–26 mm | 15–50 N | 0.8 kg | 0.3 s | 420 g | ±0.02 mm | Modbus RTU + I/O |
| EPG2-50-50 | 0–50 mm | 15–50 N | 0.8 kg | 0.5 s | 520 g | ±0.02 mm | Modbus RTU + I/O |
| EPG2-50-150 | 0–50 mm | 40–150 N | 3 kg | 0.5 s | — | ±0.02 mm | Modbus RTU + I/O |
| EPG3-10-50 | 0–10 mm | 15–50 N | 0.8 kg | 0.1 s | 400 g | ±0.02 mm | Modbus RTU + I/O |
| EPG4-10-50 | 0–10 mm | 15–50 N | 0.8 kg | 0.1 s | 450 g | ±0.02 mm | Modbus RTU + I/O |
| EPGC-50-150 | 50 mm | 40–150 N | 3 kg | 0.5 s | 1 kg | ±0.02 mm | Modbus RTU + I/O |
| EPG2-100-50 | 100 mm | 15–50 N | 2 kg | 0.7 s | 1 kg | ±0.1 mm | Modbus RTU + I/O |
| ERG-20-80 | 20 mm | 24–80 N | 1 kg | 0.2 s | 1000 g | ±0.02 mm / ±0.05° | Modbus RTU + I/O |
| ERGD-25-35 | — | 10–35 N | 0.35 kg | 0.2 s | 1000 g | ±0.02 mm / ±0.05° | Modbus RTU + I/O |
| EPGL-265-800 | 265 mm | — | — | — | — | ±0.1 mm | Modbus + I/O + EtherCAT |